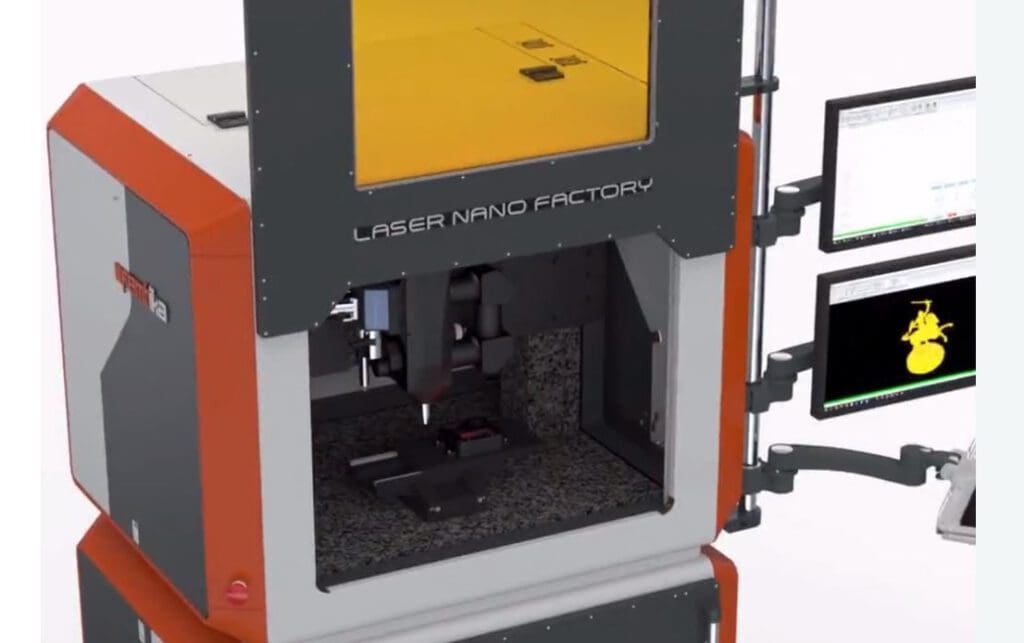
In the intricate world of 3D printing, the control system stands as the central nervous system of the printer, orchestrating the movements, processes, and interactions of various components to achieve precise and efficient printing. This system, encompassing both hardware and software, manages every aspect from the initial design file interpretation to the final execution of the print job. This article delves into the importance, functionality, and maintenance of the control system in 3D printing, highlighting its crucial role in optimizing operations and ensuring high-quality outcomes.
Importance of the Control System in 3D Printing
Coordination and Precision: The control system directs the precise movements of the printer’s mechanical parts, such as the print head, build platform, and feed mechanisms, ensuring that each layer is deposited accurately according to the design specifications.
Speed and Efficiency: By efficiently managing the sequence of operations and adjusting parameters like speed, temperature, and material flow, the control system significantly enhances the printing process’s speed and overall efficiency.
User Interface and Accessibility: Modern control systems include user-friendly interfaces that allow operators to easily configure settings, monitor print progress, and troubleshoot issues, making 3D printing more accessible to a broader range of users.
Quality Assurance: The control system continuously monitors the printing process, making real-time adjustments to maintain quality and consistency, and preemptively addressing potential issues that could affect the final product.
Components of the Control System in 3D Printers
Microcontrollers and CPUs: These are the hardware components that process all commands and control the printer’s operations. They interpret design files, translate them into actionable commands, and monitor the execution of these commands.
Firmware: The pre-installed software that provides instructions for the printer’s hardware. It includes algorithms that handle tasks such as slicing the model, determining the path of the print head, and managing temperature controls.
Sensors and Feedback Loops: Integral to maintaining accuracy, sensors provide real-time data on various aspects of the printer’s performance, such as temperature, position, and speed. Feedback loops allow the system to make automatic adjustments based on this data.
User Interface (UI): The user interface, whether on a touchscreen panel attached to the printer or through a connected computer, allows users to input commands, adjust settings, and monitor the status of the printer.
Connectivity Modules: These components enable network connectivity, allowing for remote monitoring and control, software updates, and integration with cloud-based platforms for improved functionality and resource sharing.
Installation and Calibration of the Control System
Proper Installation: Ensuring that all components of the control system are correctly installed and configured is crucial for optimal operation. This includes setting up and testing connections between the microcontrollers, sensors, and mechanical systems.
Software Configuration: Installing and configuring the necessary software and drivers is essential for the printer to operate correctly. This includes loading the correct firmware and establishing appropriate settings for the specific printer model and materials used.
Calibration: The control system requires calibration to ensure precision in printing. This involves setting the initial parameters for print head alignment, bed leveling, and material flow rates based on standard test prints.
Maintenance and Optimization of the Control System
Regular Updates: Keeping the firmware and software updated is crucial for maintaining performance and security. Updates can provide new features, improve efficiency, and fix bugs.
System Diagnostics: Regular diagnostics can help detect and rectify issues in the control system before they lead to failures or poor-quality prints. Many systems include built-in diagnostic tools to facilitate this process.
Backup Procedures: Implementing robust backup procedures for system settings and configurations ensures that they can be quickly restored in case of system failure or data loss.
User Training: Proper training for users on how to operate the control system and troubleshoot common issues is vital for maintaining operational efficiency and minimizing downtime.
Challenges and Solutions
Integration Complexity: As 3D printers become more sophisticated, integrating various components and technologies can be challenging. Employing modular control systems that allow for easier upgrades and integration with new technologies can mitigate these challenges.
Security Concerns: With increased connectivity comes the risk of security vulnerabilities. Implementing strong network security practices and regular security updates are essential to protect sensitive data and control access to the printing systems.
Hardware Compatibility: Ensuring compatibility between different versions of hardware and software within the control system is crucial for smooth operation. Regular compatibility checks and updates can help maintain system coherence and functionality.
The control system is a vital component of 3D printers, integrating complex tasks and ensuring that the printer operates smoothly, efficiently, and accurately. Effective management, regular maintenance, and careful calibration of the control system are essential for maximizing the capabilities of 3D printers and ensuring the production of high-quality, precise, and reliable printed products. By thoroughly understanding and meticulously maintaining the control system, manufacturers can achieve improved operational reliability and enhanced print quality, fully leveraging the advanced capabilities of 3D Printers.